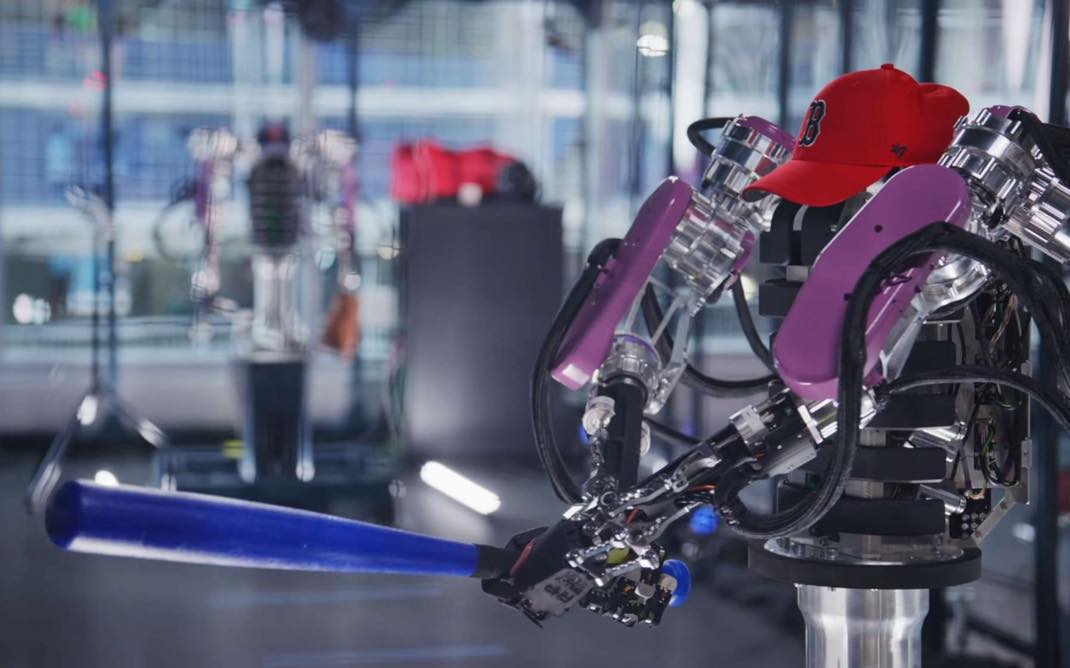
A Torso-Only Platform Built for High-Speed Ball Tracking
AthenaZero fires a baseball at roughly 113 kilometers per hour, hauls in incoming projectiles at nearly 66 kilometers per hour, and connects with 82% of pitches during batting trials. Developed by the Robotics and AI Institute and detailed in research published on Science, the two-armed platform was engineered specifically to test mechanical precision and dynamic control through baseball exercises. The stationary system lacks legs or wheels. Instead, it relies on a pivoting torso to support two active arms and specialized hands, using centralized mass distribution to accelerate reaction times. Conceived around the athletic gesture rather than adapting athletic movements to a machine built for tightening factory bolts, the robot performs throwing, catching, and batting tasks with the same body.
Mechanical Compliance Versus Rigid Industrial Design
Conventional industrial gearboxes prioritize rigid precision over flexibility. In contrast, engineers at the Robotics and AI Institute designed lightweight actuators that yield slightly when subjected to external force. Low-inertia joints and torso-mounted heavy motors allow the robotic limbs to absorb high-speed impacts rather than resisting them rigidly. This mechanical compliance enables the machine to cushion the force of a catching motion. This approach could revolutionize humanoid robot precision, as robots like 1X’s Neo already focus on more delicate manipulation, demonstrating that the next step in robotics is learning to precisely dose a robot’s gestures when interacting with sensitive environments or humans rather than merely increasing strength or speed.
Bridging the Gap Between Warehouse Humanoids and Elite Athletics
Major league pitchers generate internal shoulder rotation speeds reaching roughly 7,000 degrees per second to throw fastballs near 150 kilometers per hour. Modern electric actuators operate under entirely different physical constraints. According to reporting by Futuro Prossimo, warehouse humanoid robots designed for high torque and slower movements cannot handle the dynamic demands of athletic coordination. Traditional robotics laboratories typically assign separate, single-purpose robotic arms to each distinct action. AthenaZero attempts to bridge that gap by completing throwing, catching, and batting tasks with a single chassis.
Tackling Tactile Perception and Real-Time Latency Challenges
Achieving stable manipulation requires more than fast motors and lightweight framing. Futuro Prossimo noted that integrating distributed tactile sensors, conductive skins, and deformable circuit boards remains essential for a mechanical body to register exact impact points rather than merely stopping a projectile. Professional batters evaluate oncoming trajectories in roughly 400 milliseconds, highlighting the latency challenges engineers face when synchronizing perception, computation, and mechanical actuation in real time. Sport robotics relies above all on perception, where measuring gripping force matters more than lifting heavy weights.
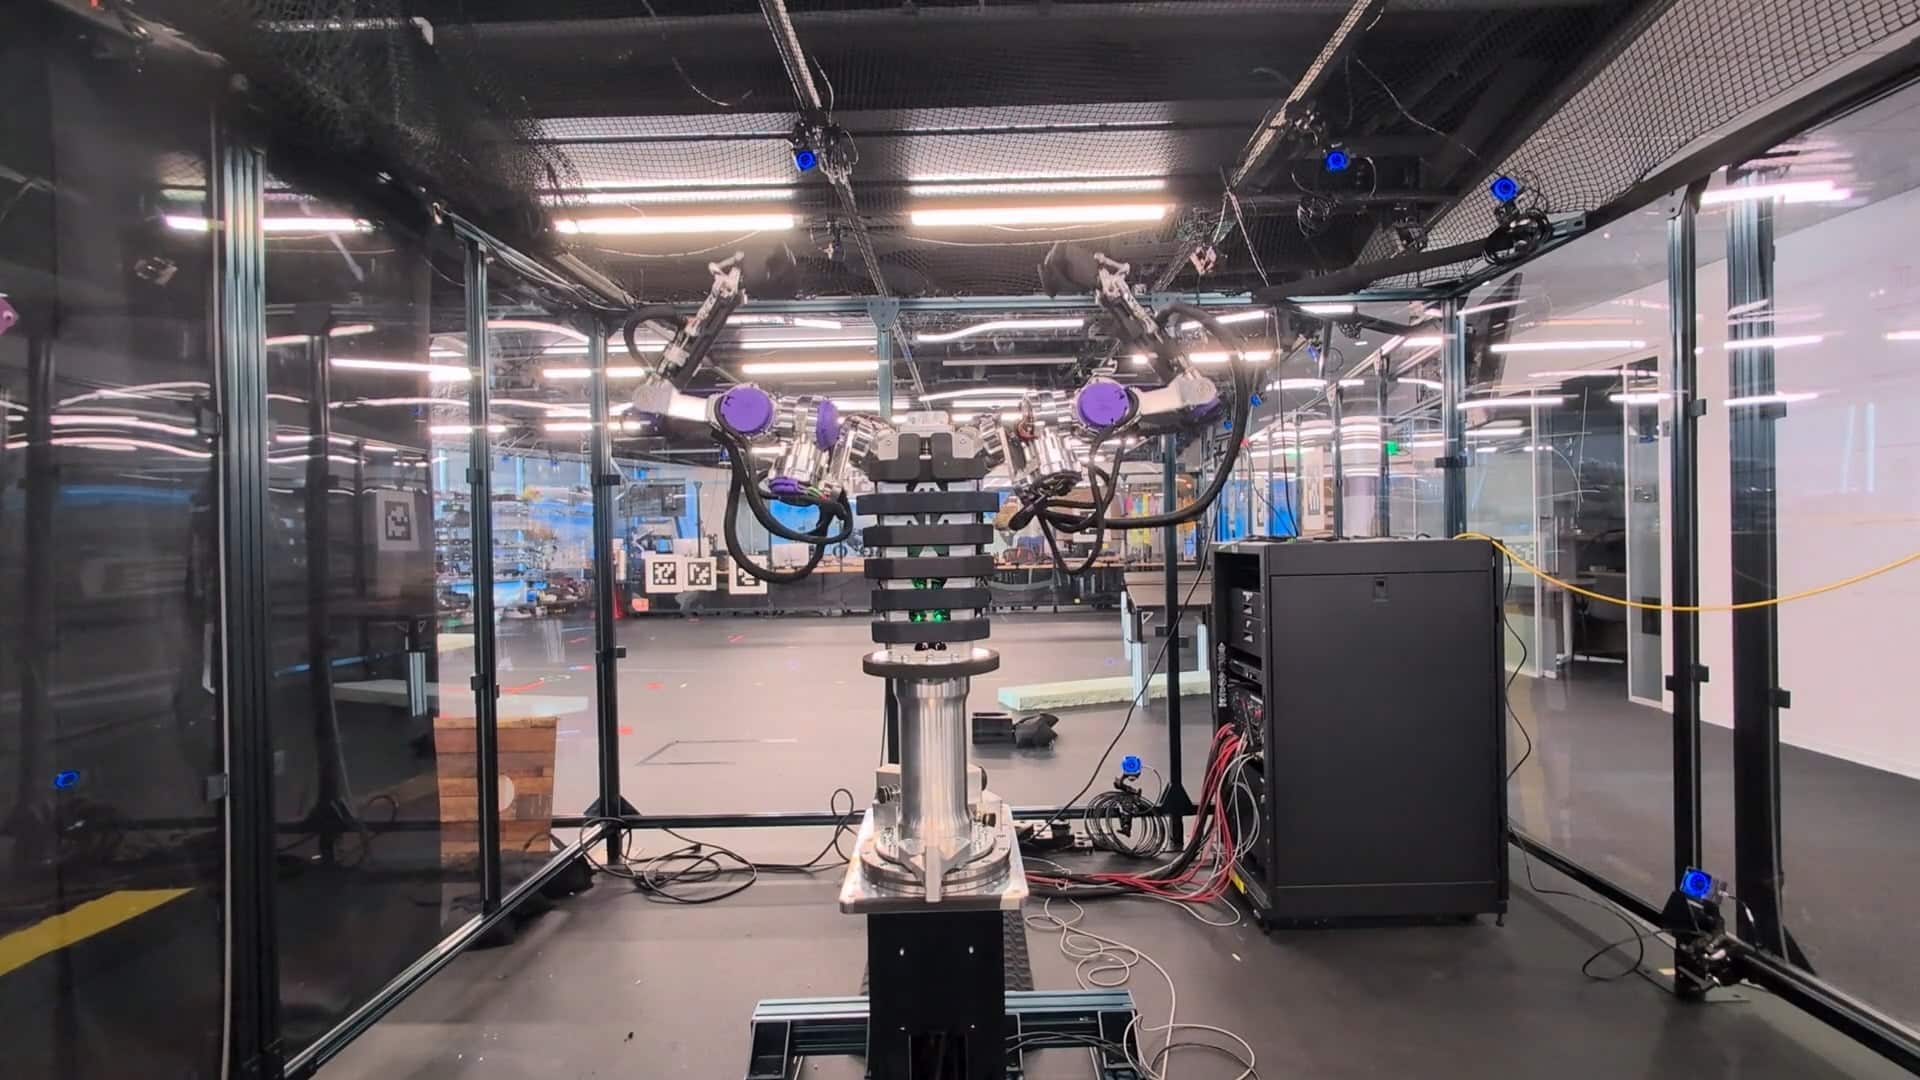
Eight to Fifteen Years Before Real-World Trajectory Mastery
Independent analysts and robotics researchers estimate that achieving reliable mastery over unpredictable real-world trajectories will require eight to fifteen years of further development. Current engineering hurdles include the limited power density of electric actuators for maximum angular velocity, ongoing latency within perception-action chains, and mechanical wear resulting from repeated impulse loads. Early beneficiaries will be logistics and surgical robotics rather than sports stadiums, where fast and precise movements represent a genuine asset.
Worth a look


