Researchers at the Robotics and AI Institute have developed AthenaZero, a stationary, two-armed robotic system designed to perform complex athletic movements such as catching, throwing, and striking baseballs with human-like fluidity, heise online reported.
Engineering the AthenaZero Robotic Arms for Dynamic Manipulation
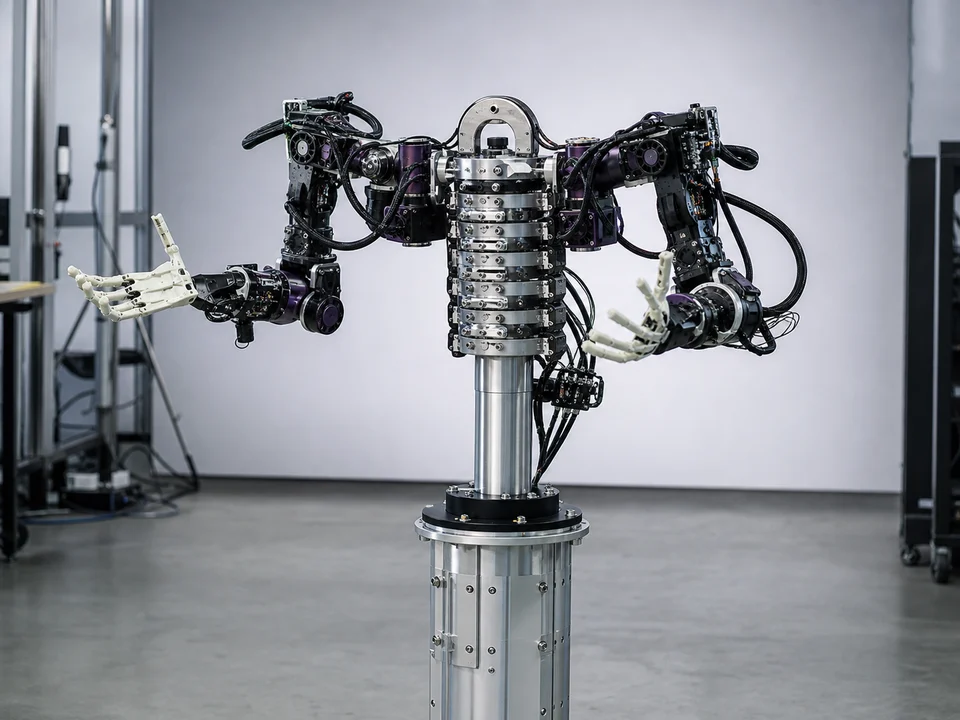
Human movement requires intricate coordination and rapid actuation, qualities that roboticists have historically struggled to replicate in artificial limbs. While previous humanoid robotics projects focused heavily on bipedal locomotion and walking mechanics, the Robotics and AI Institute concentrated its engineering efforts exclusively on upper-body arm movements. The resulting AthenaZero system features a static torso mounted with two highly agile arms, omitting hips, legs, feet, and a head entirely.
Details of the mechanical design were published in the study titled “AthenaZero: A low-inertia, bimanual robot for dynamic manipulation” in Science Robotics. The research team set out to determine whether a rigid robotic core could achieve mass and torque properties comparable to those of a human athlete. Although the structural elements of the arms rely on rigid components, the joints utilize fast-reacting actuators designed to yield upon impact. This mechanical compliance allows the system to maintain controlled motion even when physical contact introduces external forces.
Executing Baseball Drills with Compliant Actuation
To test the limits of the hardware, the institute selected baseball as a demonstration environment due to its high demand for speed, precision, and variable force regulation. The AthenaZero system successfully caught incoming balls, executed powerful throws, and swung a bat against pitched objects. When a ball strikes the robotic hand, the compliant joints automatically absorb the impact energy and distribute it across the entire kinematic chain of the machine.
Each robotic arm terminates in a three-fingered hand capable of broad articulation. By dynamically adjusting joint compliance depending on the load, the machine handles delicate catches and forceful releases without stalling or fracturing its internal gears. The institute plans to build on these baseline demonstrations to tackle more generalized manipulation tasks in unpredictable real-world environments.
Frequently Asked Questions About AthenaZero
What components are missing from the AthenaZero robot? The stationary system consists solely of a rotatable torso and two arms, omitting a head, hips, legs, and feet entirely.
Where was the technical study published? The research findings detailing the low-inertia bimanual design appeared in the academic journal Science Robotics.
How do the robot’s joints handle sudden impacts? The joints feature fast-reacting actuators configured to yield under external force, absorbing and dissipating impact energy across the kinematic chain.
Related reading