AthenaZero represents a fundamental shift in sports robotics, designed by researchers to execute throwing, catching, and batting gestures from a single, unified body rather than utilizing disparate industrial arms.
Robotics engineers frequently encounter a complex friction point when attempting to integrate high-speed athletic movements into mechanical platforms. Conventional warehouse humanoids rely on high torque outputs and slow motion profiles built for industrial tasks like screwing factory bolts. According to the Robotics and AI Institute, AthenaZero reverses that conventional engineering framework by prioritizing athletic gestures and dynamic manipulation directly into its structural design.
The Engineering Challenges of Athletic Robots
Dynamic manipulation remains a notoriously difficult hurdle in modern robotics. Catching a moving baseball requires calculating trajectory angles, closing a mechanical hand, and absorbing kinetic impact within a tight time frame. Professional baseball hitters accomplish this sequence in approximately 400 milliseconds, dedicating a substantial portion of that window simply to processing visual data and recognizing the approaching pitch.
Traditional factory systems cannot operate within that rapid timeframe. AthenaZero addresses this limitation by incorporating lightweight, fast actuators and shifting physical masses toward the central trunk. Its control architecture is initially trained in simulation environments before being successfully transferred to the hardware platform, allowing the robot to execute throwing, catching, and batting actions using the exact same physical body.
Comparing Human Velocity and Robotic Limits
Physical comparisons highlight the immense gap separating current robotic technology from elite human athletes. Biomechanical data shows that the shoulder joint of a Major League pitcher internally rotates at roughly 7,000 degrees per second—marking the fastest voluntary human movement ever recorded—and propels a baseball near 150 km/h.
By comparison, current electric actuators operate an entire order of magnitude below those biological extremes. According to project disclosures, AthenaZero currently throws comparably to a kid in the garden. The primary bottleneck is not generating raw force, but achieving extreme dexterity and millisecond precision.
Perception, Materials, and Practical Applications
Advancing athletic robotics requires sophisticated sensory materials rather than brute power alone. AthenaZero integrates distributed tactile sensors, conductive skins, and printed circuits laid across deformable surfaces. A robotic system designed to absorb the sudden impact of a baseball must physically register where the collision occurred across its structure, transforming athletic robotics into a gamble on advanced perception.
Engineering estimates suggest it will take between 8 and 15 years before robotic platforms achieve reliable grasping capabilities on unpredictable trajectories in real-world environments. Current obstacles include the limited power density of electric actuators during peak angular velocity, latency within perception-action loops, and mechanical degradation under repetitive impulsive loads.
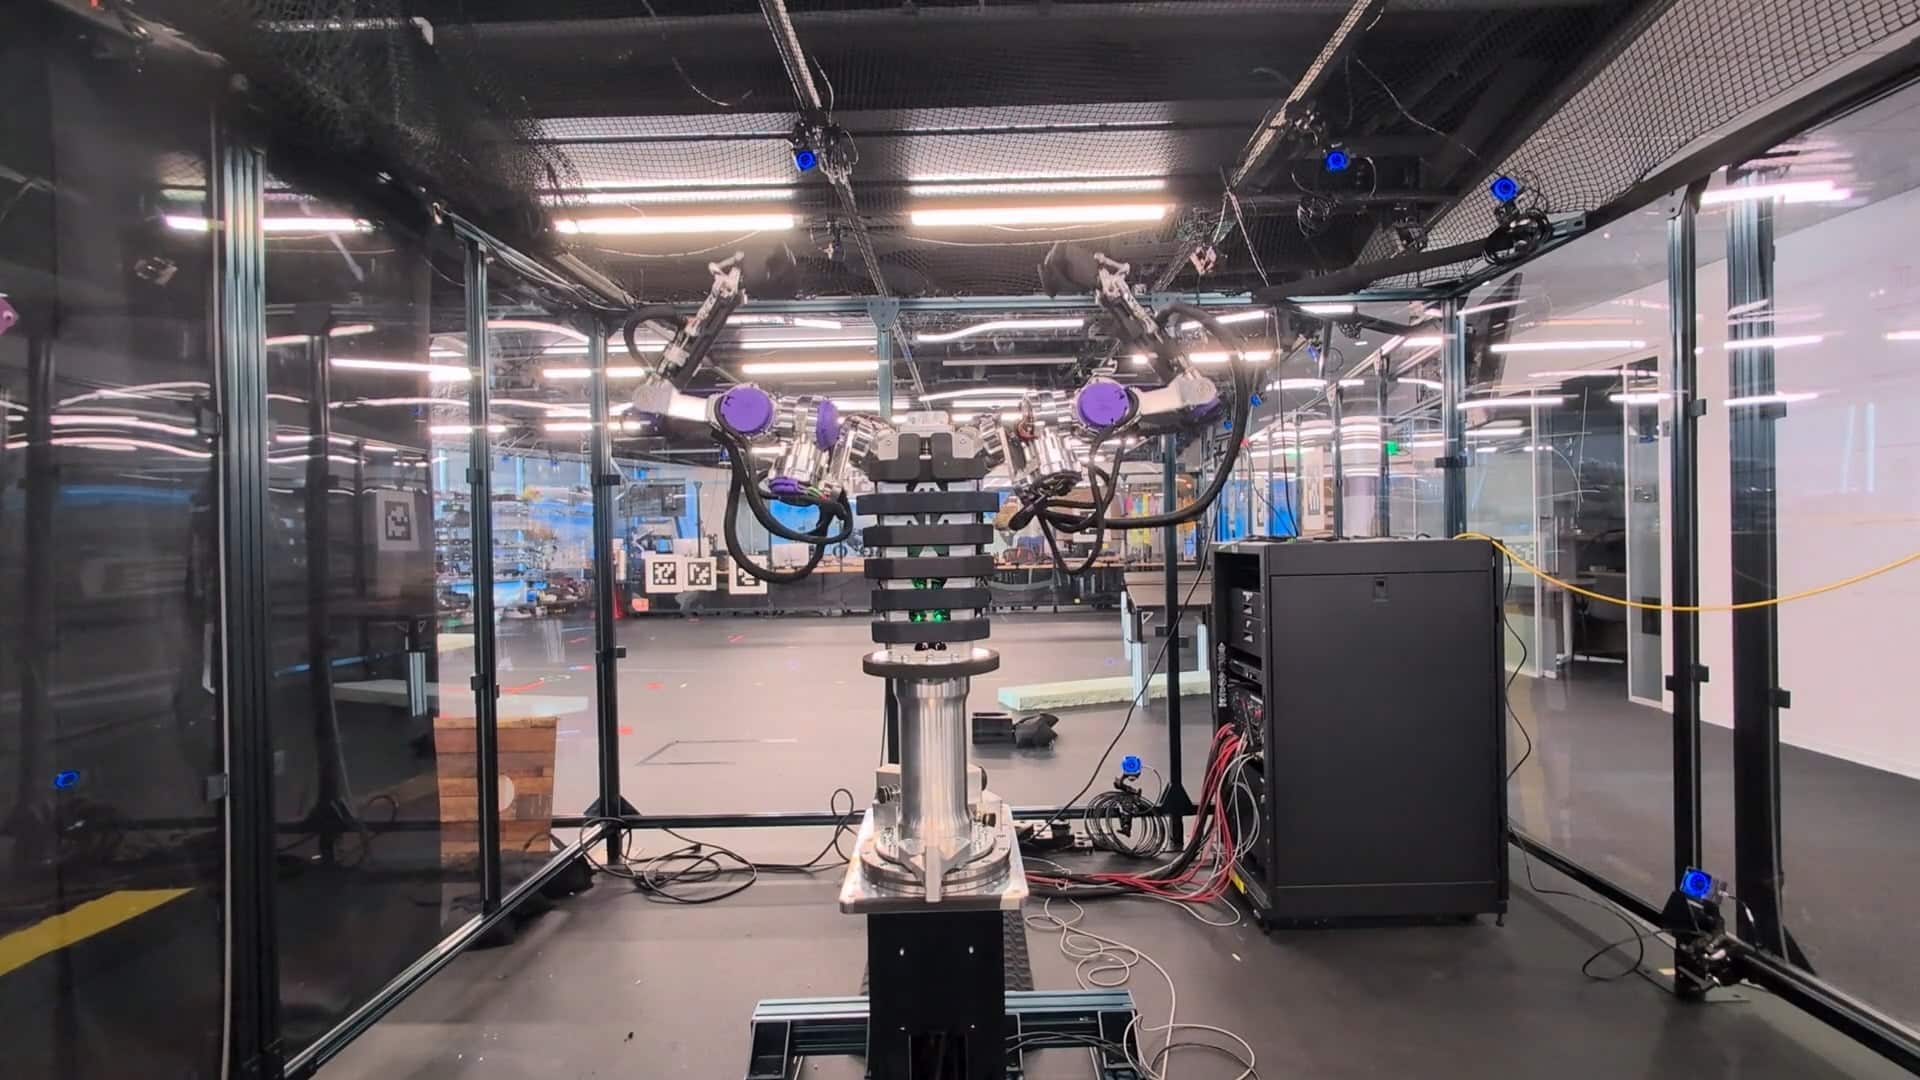
Researchers note that the earliest beneficiaries of these perception-driven robotics will likely extend far beyond professional sports stadiums. Logistics automation and surgical robotics stand to gain significantly from rapid, highly calibrated physical movements where split-second precision carries immense practical value. For now, AthenaZero remains a dedicated research platform—resting in its testing cage with its arm frozen midair while capture cameras continue logging data.
Keep reading