A Single Chassis for Three Baseball Disciplines
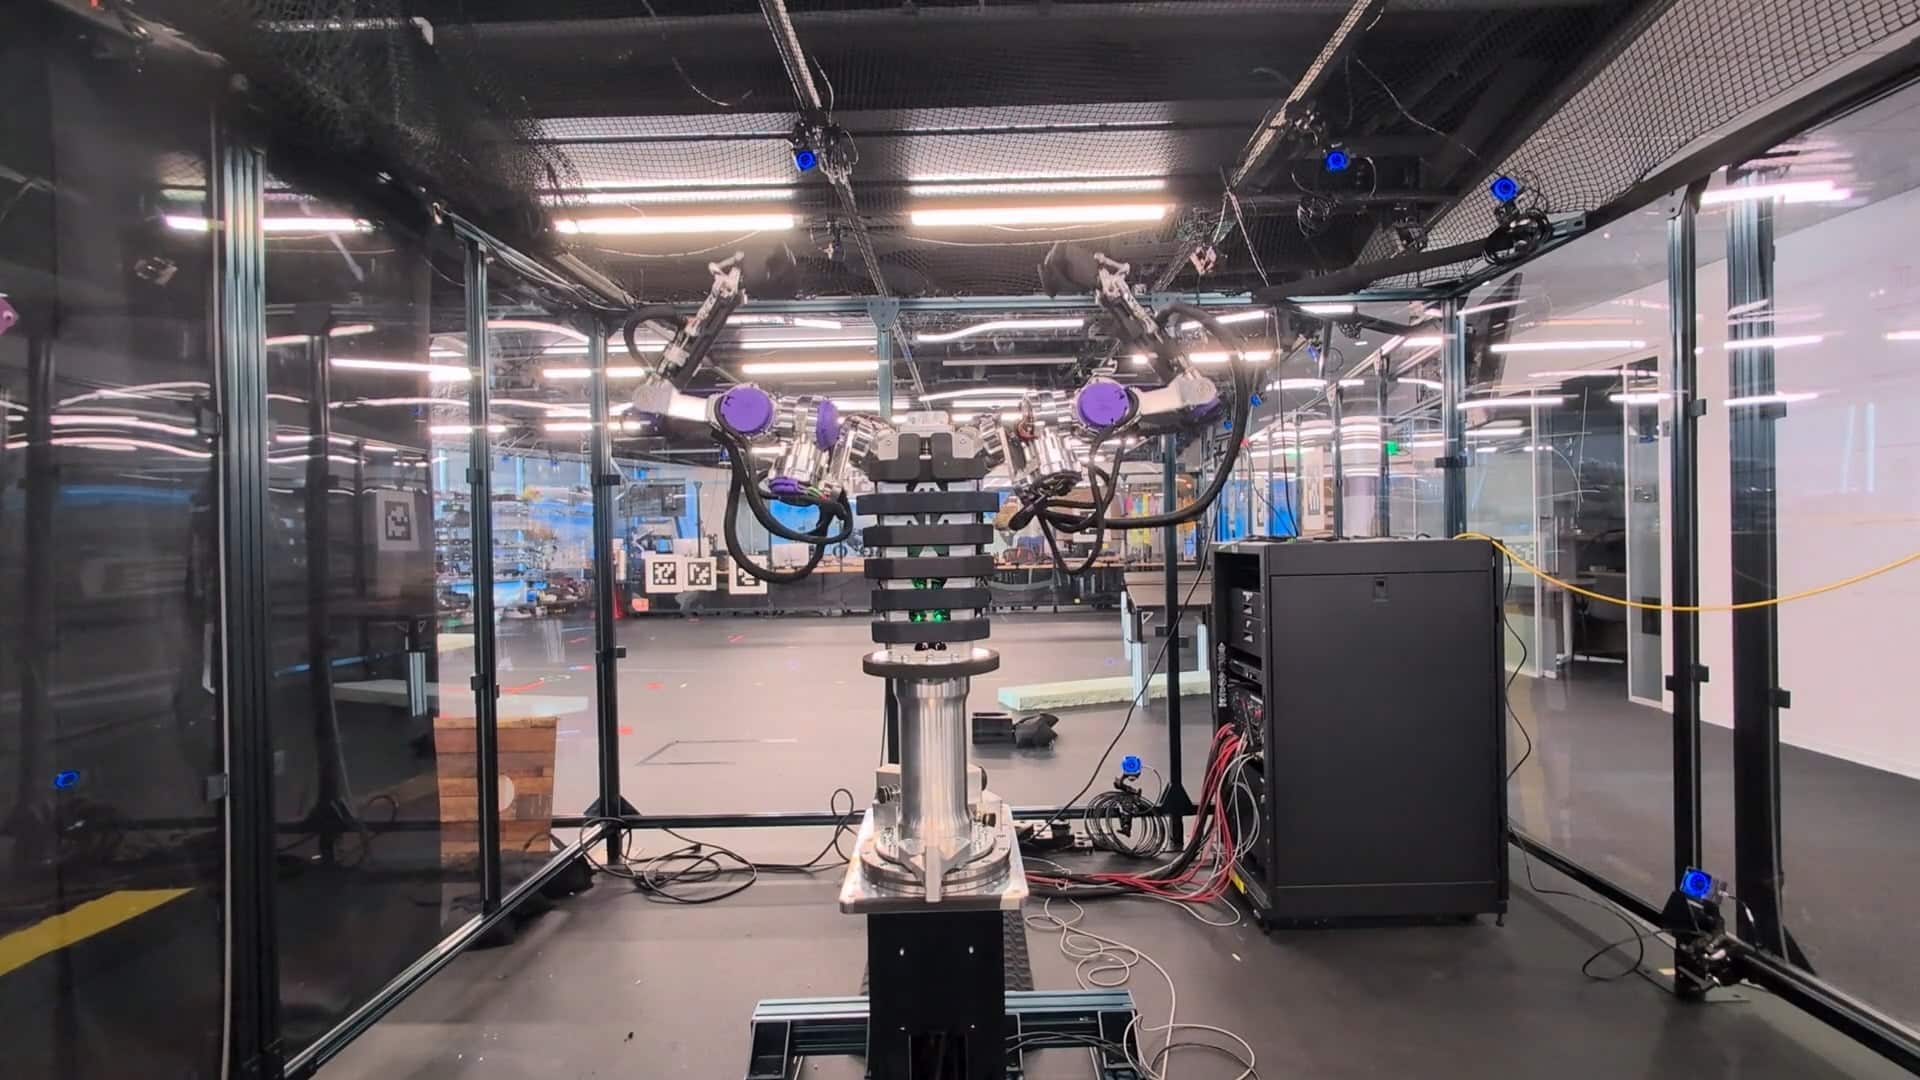
AthenaZero, a dual-armed robotic system developed by researchers and detailed by the Robotics and AI Institute, has successfully demonstrated the ability to pitch, catch, and hit a baseball using a single integrated chassis. The project serves as an engineering testbed for dynamic manipulation, tackling one of the most complex mechanical challenges in modern robotics: coordinating rapid physical responses within tight temporal windows.
Traditional athletic training machines found in batting cages rely on fixed-speed mechanical wheels that fire rubber balls repeatedly to a single point. According to reports from the Robotics and AI Institute, AthenaZero was designed instead around the human athletic gesture, housing its mechanics within a single body capable of performing multiple distinct baseball movements rather than assigning each task to a specialized industrial robotic arm.
Beating the 400-Millisecond Human Reflex Window
Dynamic manipulation remains a demanding hurdle in robotics. Catching a flying baseball requires a machine to estimate an incoming trajectory, close a manipulator hand, and absorb kinetic impact within a compressed timeframe.
Professional baseball batters typically evaluate and react to pitches in approximately 400 milliseconds, a window that challenges warehouse humanoids built for high-torque and slower movements.
Overcoming Actuator Limits and Physics
To address these speed requirements, AthenaZero features lightweight and fast actuators with mass distributed closer to its central trunk. Its control system was trained through simulation before being transferred to physical hardware.
While Major League Baseball pitchers achieve shoulder internal rotation speeds of roughly 7,000 degrees per second and throw velocities near 150 km/h, current electric actuators operate at significantly lower thresholds, meaning the robot currently pitches at speeds comparable to a youth player.
The Decade-Long Timeline for Real-World Tactile AI
Engineering challenges extend beyond raw velocity into the realm of perception and materials. Developers utilize distributed tactile sensors, conductive skins, and printed circuits on deformable surfaces to help the machine register where impacts occur.
Robotics researchers indicate that building reliable catching systems for unpredictable real-world trajectories will require between 8 and 15 years of development, driven by improvements in actuator power density and reduced latency in the perception-action chain.
Beyond the Diamond: Logistics and Surgery
For now, AthenaZero functions primarily as a research platform equipped with a glove.
While athletic stadiums are unlikely to field robotic players in the near term, advancements stemming from athletic robotics are expected to influence fields such as surgical robotics and logistics, where rapid, calibrated physical manipulation is required.
Worth a look