Athena Zero Dual-Arm Baseball Robot Throws and Hits
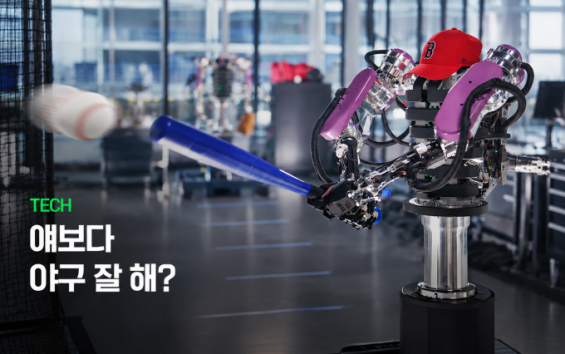
Researchers in the United States have unveiled Athena Zero, a dual-arm robot capable of throwing a baseball at 77.04 km/h and catching incoming pitches, according to research published in the international journal Science Robotics on September 16. The system achieves an 82% success rate when making contact with incoming pitches using a bat, matching speeds close to those of an amateur human pitcher.
Unlike traditional industrial robotic arms that rely on multiple layers of reduction gears to multiply force, Athena Zero utilizes a specialized motor design with fewer reduction gears. While reduction gears help motors achieve precise movements, they typically add weight and stiffness to robotic limbs. By minimizing these gears and placing heavy motors close to the robot’s torso, the research team reduced arm weight and inertia.
This structural adjustment allows the robot to accelerate its arms rapidly, change direction swiftly, and halt motion precisely to time the release of a pitch. The lighter limbs also absorb impact forces smoothly during catches, mirroring the shock absorption of a human arm. With lighter equipment, the robot successfully threw light tennis balls at speeds up to 110 km/h during testing.
Testing and Future Applications in Robotics
During trials, Athena Zero engaged in catch-and-return drills and batting practice sessions with both humans and other robotic systems. The development team designed the machine to handle high-speed, dynamic interactions without the rigidity that hampers conventional automation hardware.
Researchers noted that the design principles behind Athena Zero—specifically the reduction of heavy gearboxes and optimized motor placement—could pave the way for machines that interact and work safely alongside humans in dynamic environments where physical contact occurs.
Related reading